Project 02 · Dynamic mobile manipulation

evoBOT

Balancing locomotion and manipulation as one system.

A two-wheeled, dynamically stable robot with manipulators for receiving, transporting and transferring loads.

Initial idea and conceptTeam-built prototypeFirst-author IROS paper · 2023
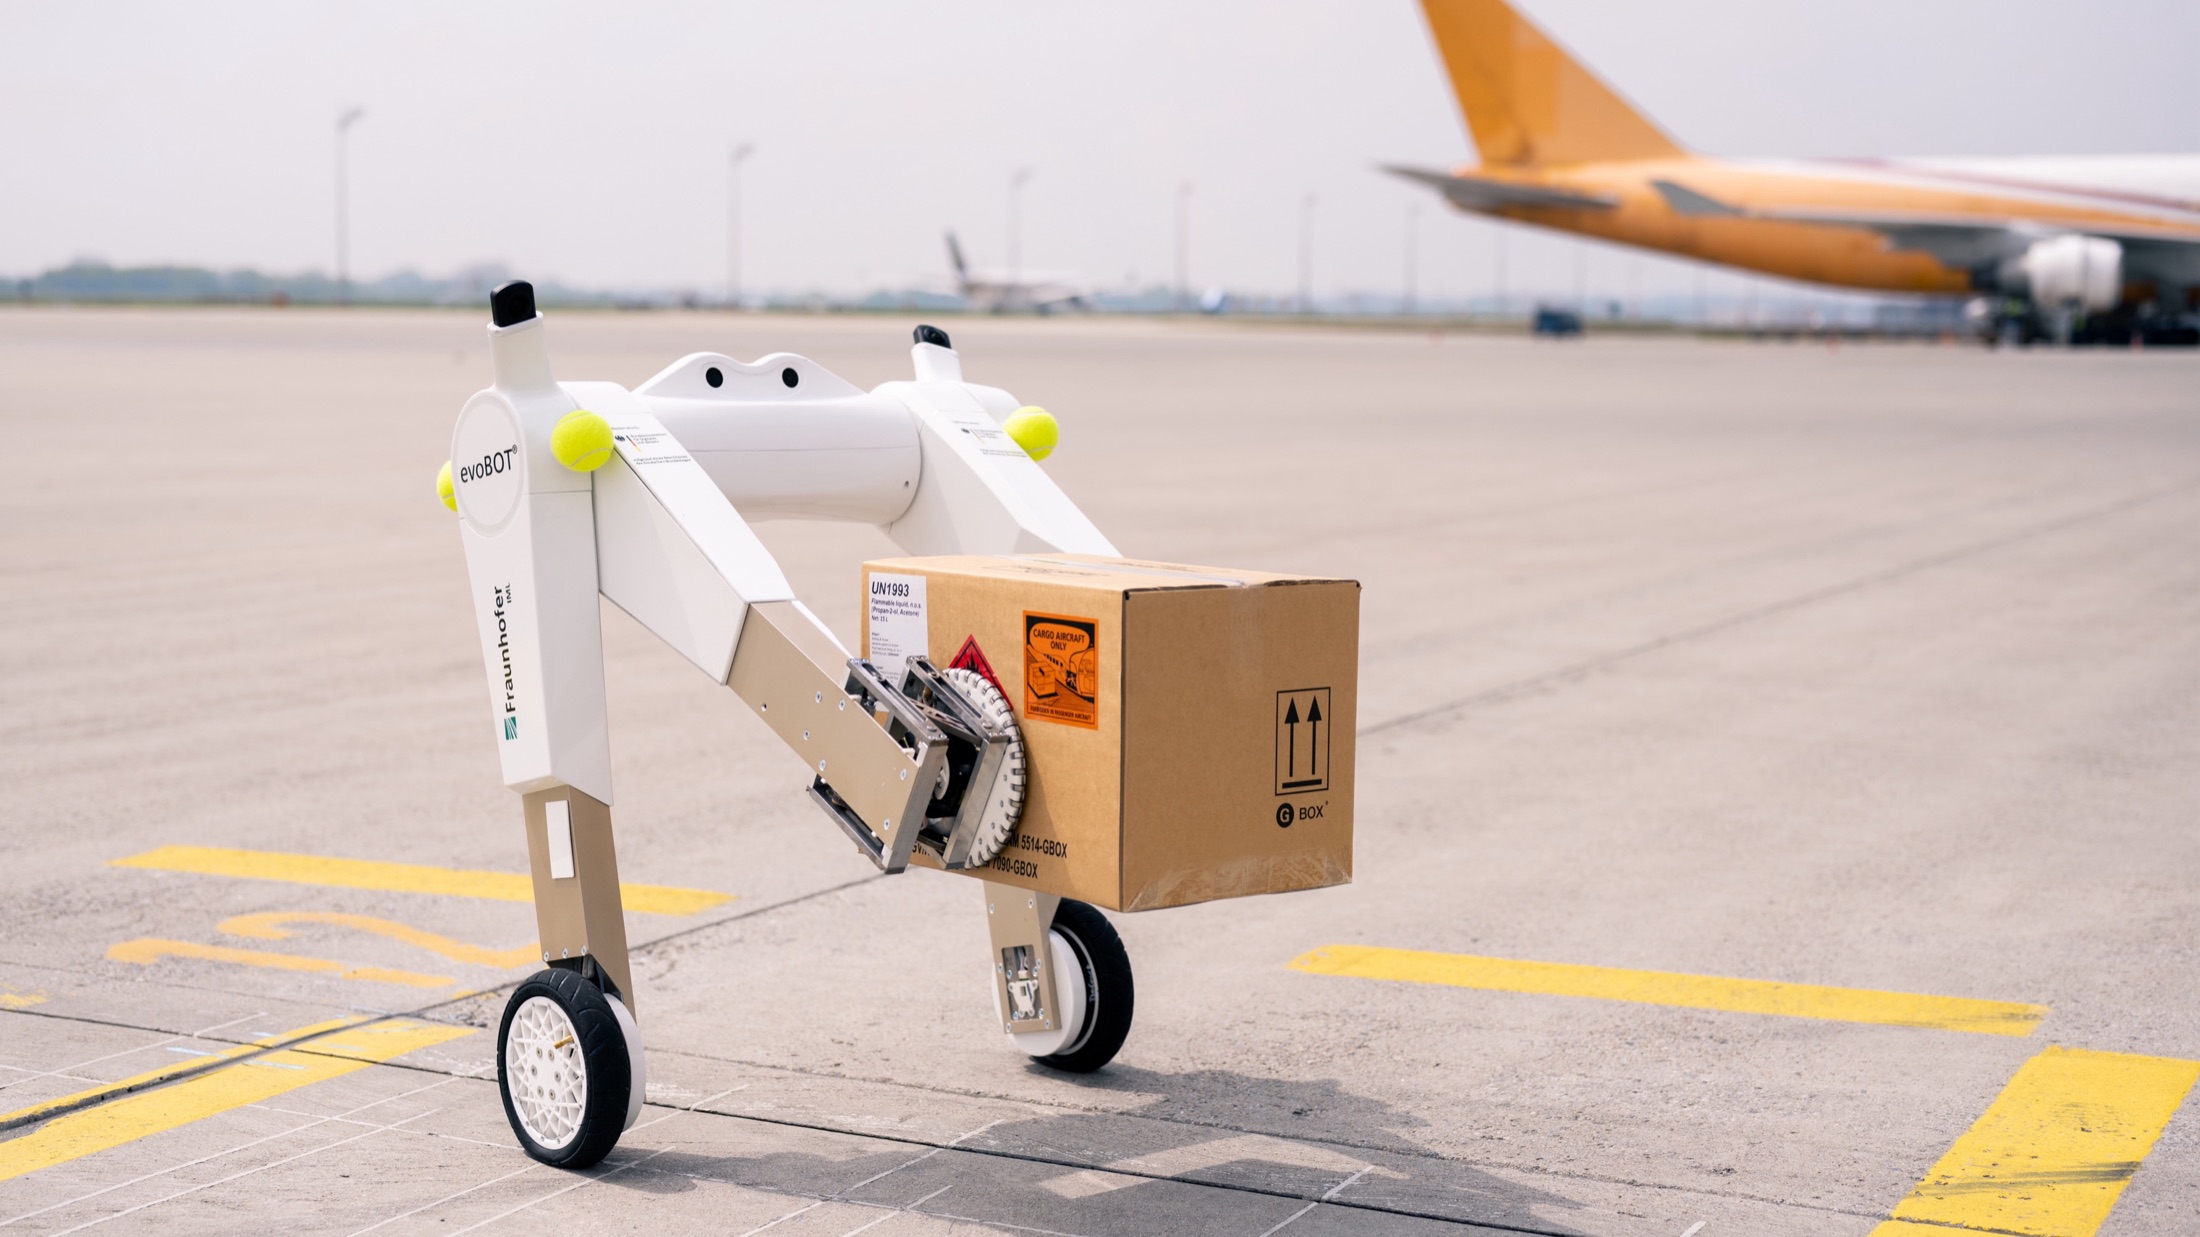
evoBOT transporting an air-cargo package on an airport apron.
evoBOT in a later air-cargo application environment.Image credit pending final confirmation

The platform

Dynamic stability meets active load handling.

evoBOT is based on the compound inverted-pendulum principle. Its compact chassis and lateral manipulators combine agile transportation with active pickup and handover of loads. Published performance figures vary between prototype generations, so this page does not mix version-specific speed claims.

2 wheels
dynamically stable chassis
2 arms
active load manipulation
IROS ’23
peer-reviewed publication

Attribution

Team achievement

A coupled multidisciplinary platform.

The prototype brought together mechanics, electronics, sensing, actuation, control, navigation and manipulation. It was built by a Fraunhofer IML team. Subsequent platform generations and later field trials involved additional contributors.

My contribution

From first sketch to integrated prototype.

I developed the initial idea and concept sketch, then built the prototype with the team. I led the first two years of core development and kept an eye on integration across the full system. My main technical contribution was motion control and state estimation.

Technical focus

A coupled control problem.

The chassis is inherently unstable. Useful manipulation therefore depends on treating balance, locomotion and arm motion as connected dynamics.

Motion control

Stabilize the two-wheeled chassis while producing purposeful translational and rotational movement.

State estimation

Estimate the robot’s dynamic state reliably enough for balance and motion control.

System integration

Coordinate sensing, actuation, mechanics and software as one working prototype rather than isolated subsystems.

Public evidence

Research and invention.

I am the first author of the 2023 IROS paper on the robot’s design and learning-based control. The German evoBOT patent family covers receiving, transferring and transporting load carriers. After the first two years of core development under my leadership, the platform continued to evolve through later air-cargo trials.

No connection to YouTube is made until the button is activated. Open on YouTube instead ↗