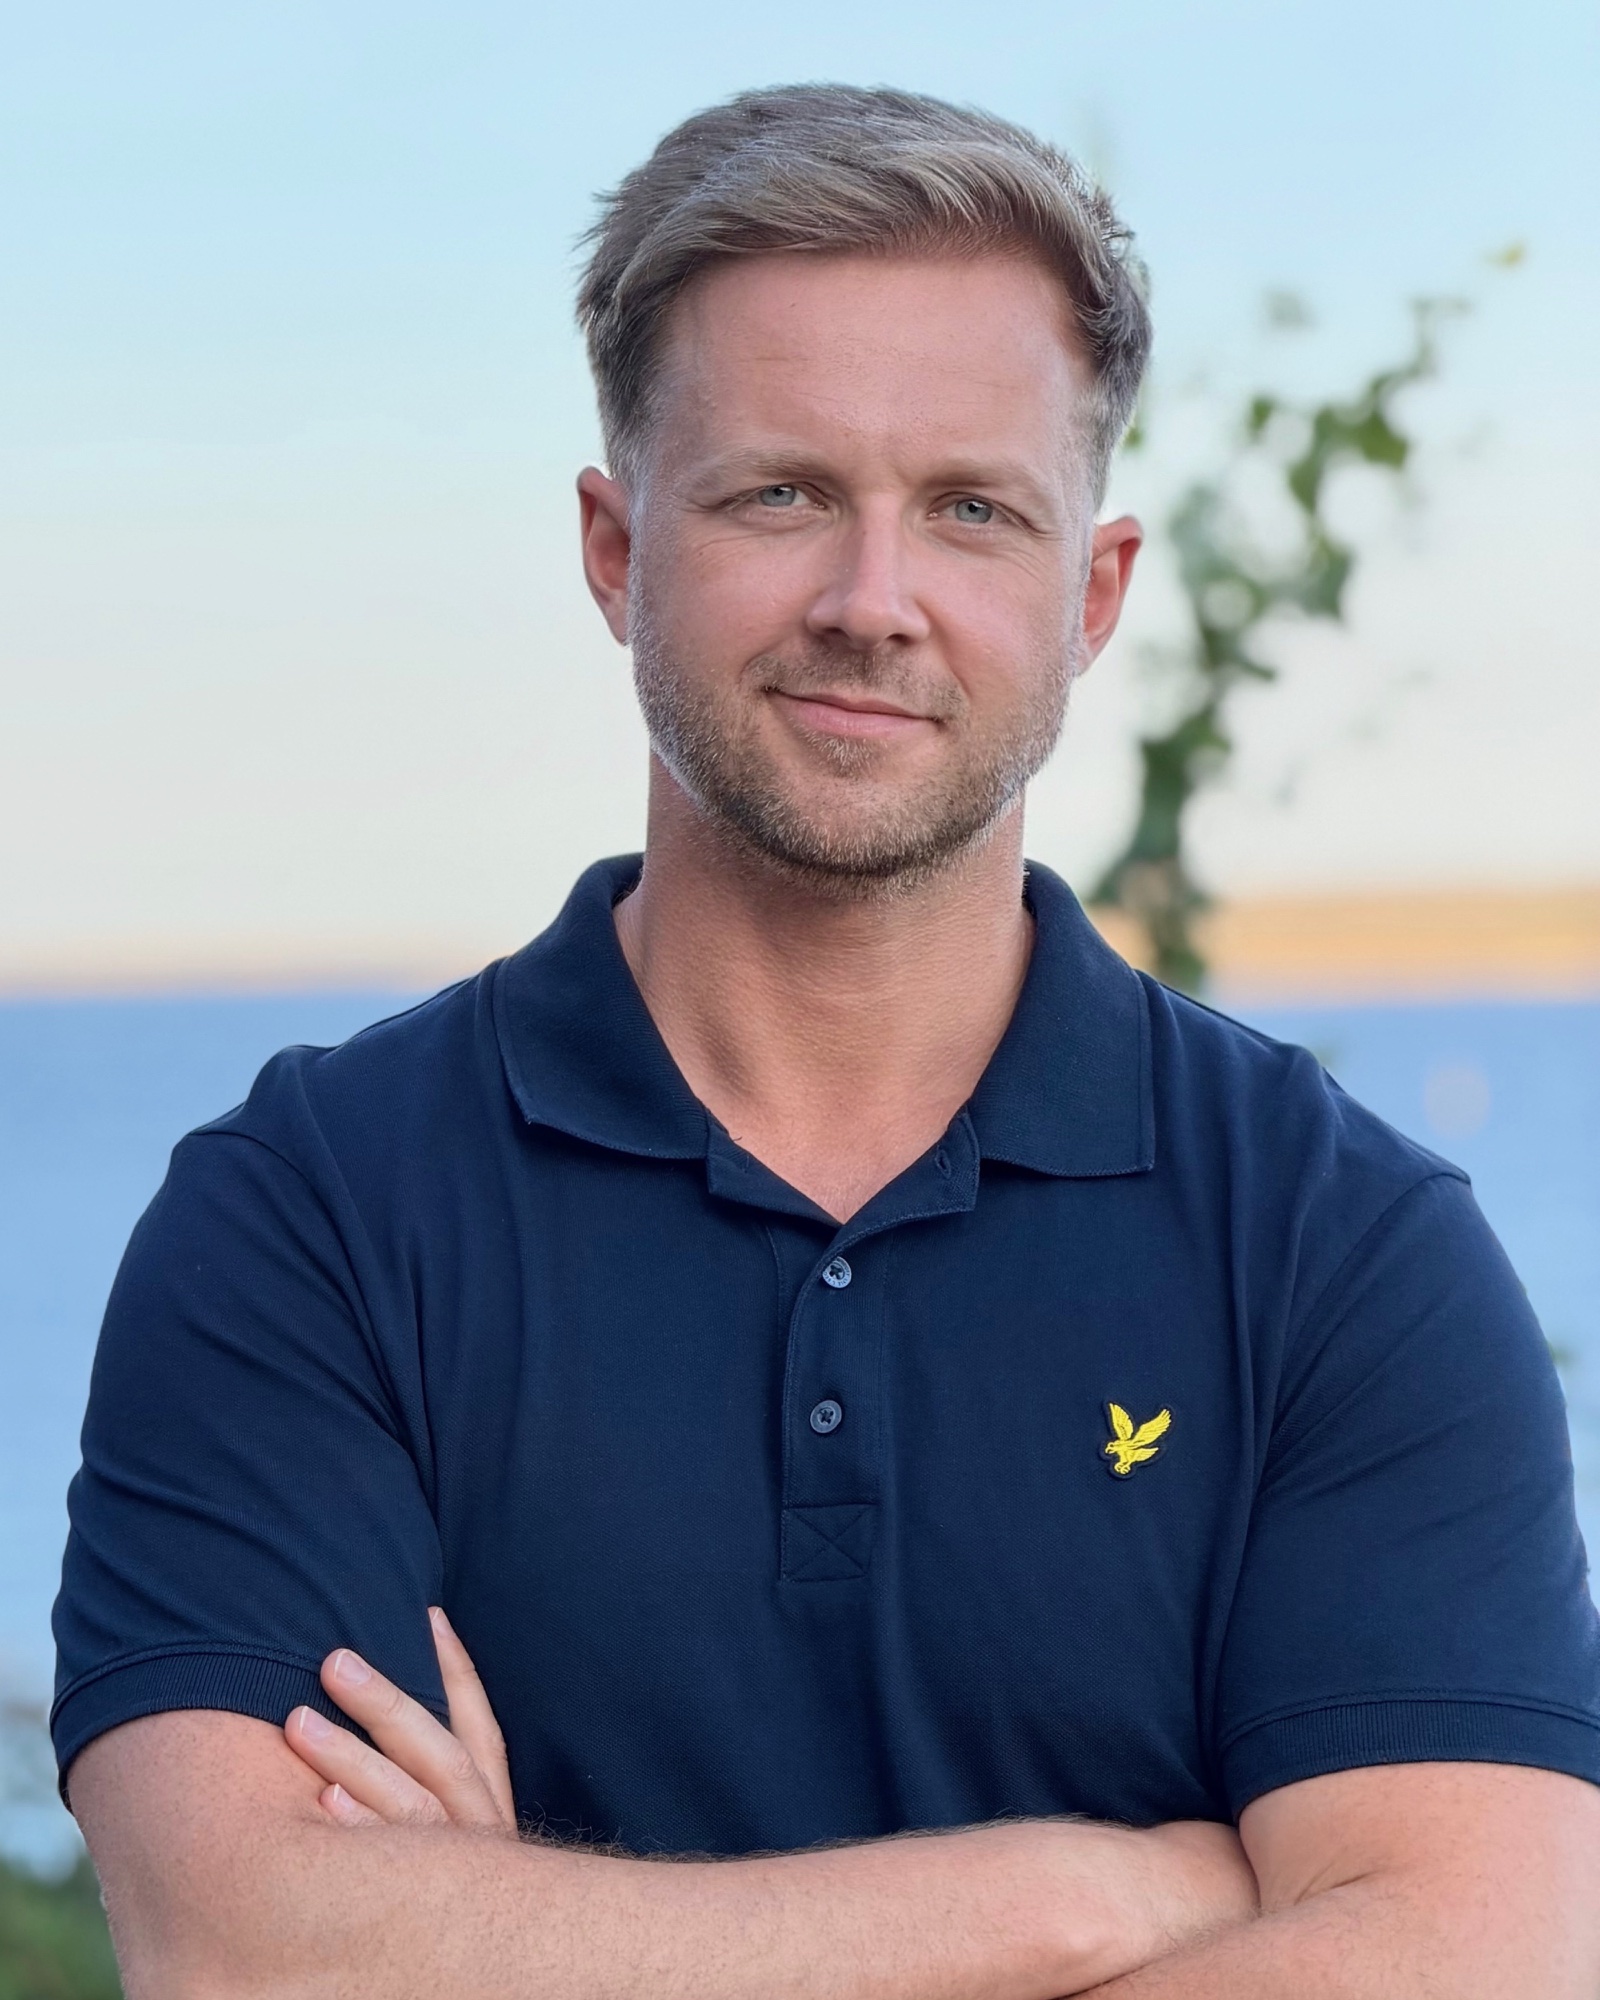
Portrait of Patrick Klokowski, robotics researcher and technical team lead.

Robotics · Control systems

I’m Patrick Klokowski.

Control. Coordination. Robots in motion.

I design and implement control systems for high-dynamic robots, from feedback control and state estimation to trajectory generation and coordinated fleets.

Robotics researcher and technical team lead at Fraunhofer IML in Dortmund. My work spans LoadRunner, evoBOT and experimental multi-robot systems.

Dortmund, Germany · PhD March 2027

Selected work

Robots I’ve built.

These systems were developed by multidisciplinary teams. Here is what we built and what I contributed.

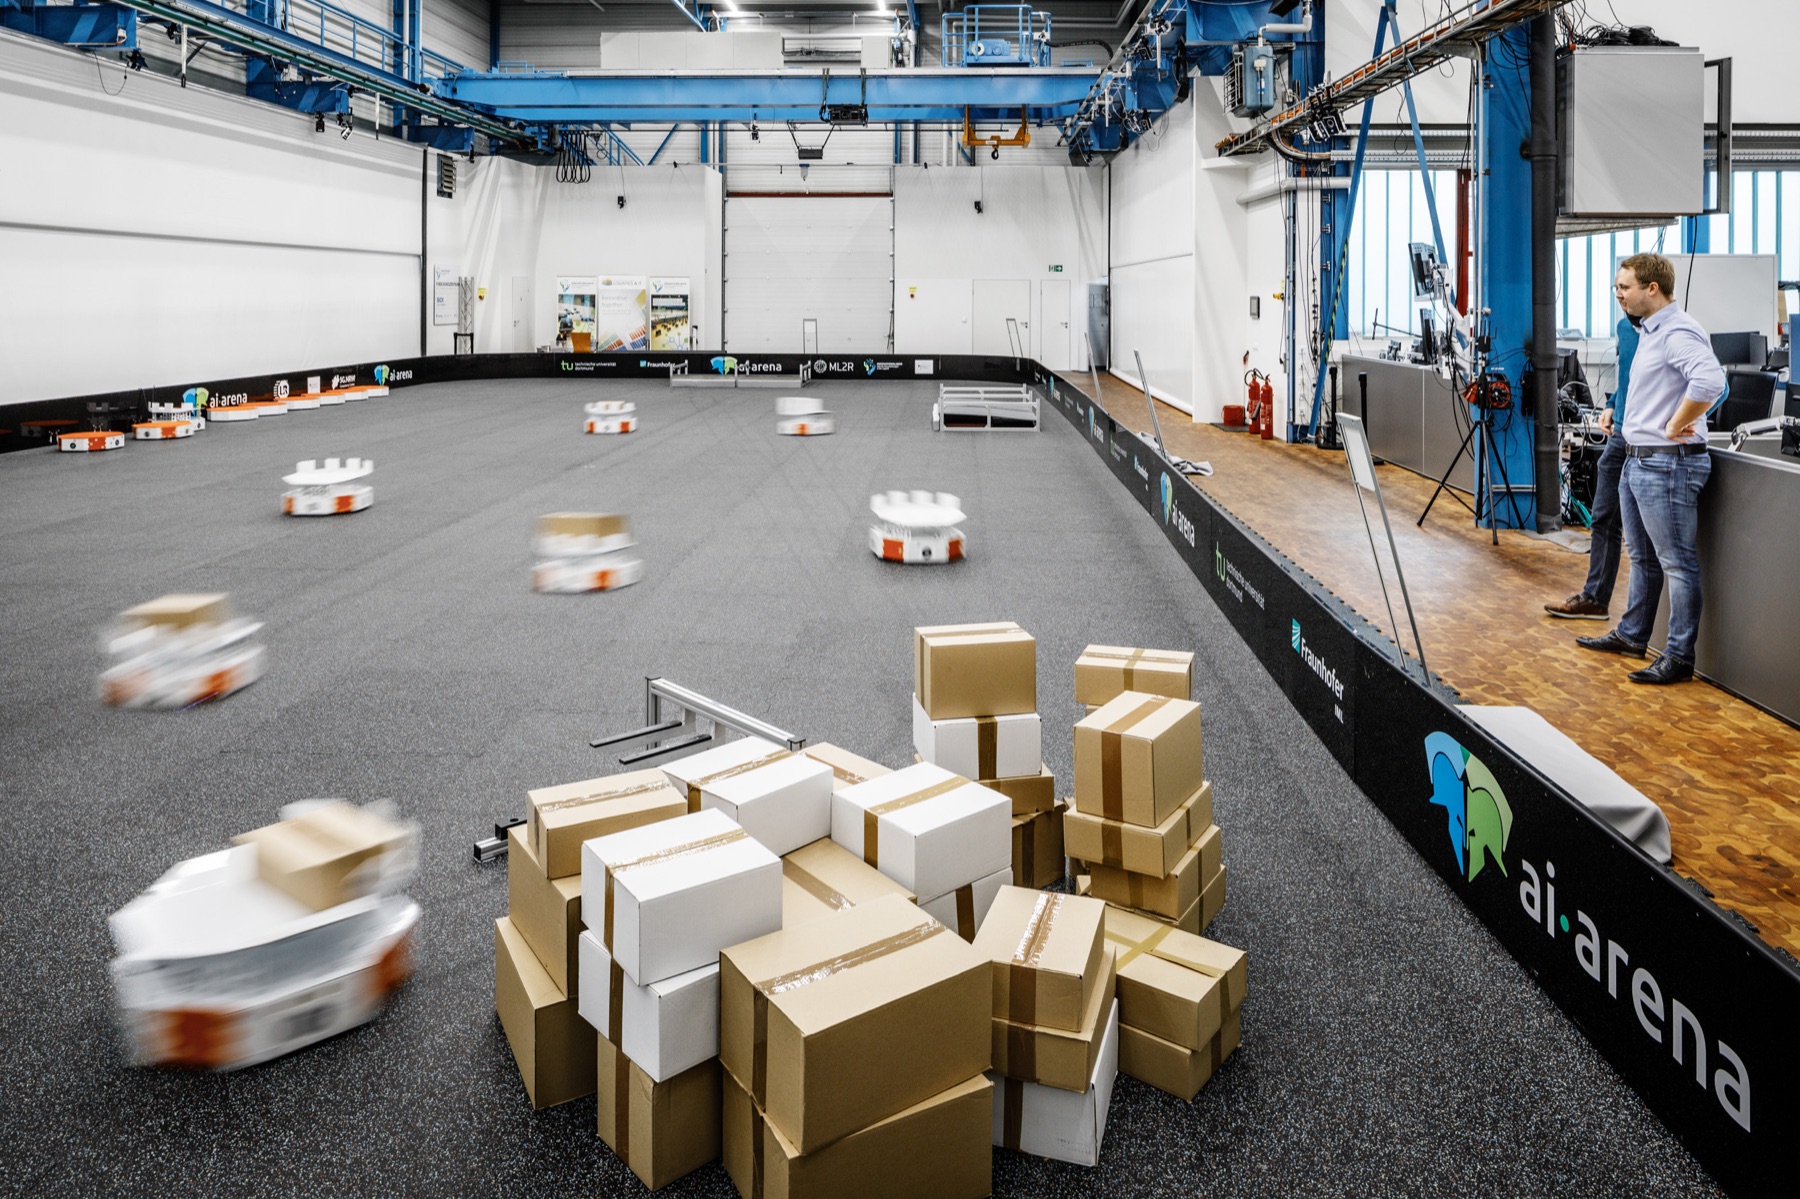
LoadRunner robots sorting parcels in a research hall.01

High-dynamic transport

LoadRunner

High-dynamic, omnidirectional transport robots for coordinated material flow.

Team achievement
A robot system combining mechanics, electronics, localization, motion control and fleet coordination, with a field trial at DPD’s Cologne-Porz facility in 2023.
My contribution
I helped shape the system concept and implemented feedback control, state estimation, trajectory generation and fleet orchestration.
Up to 10 m/s · reported platform capability
Open project →
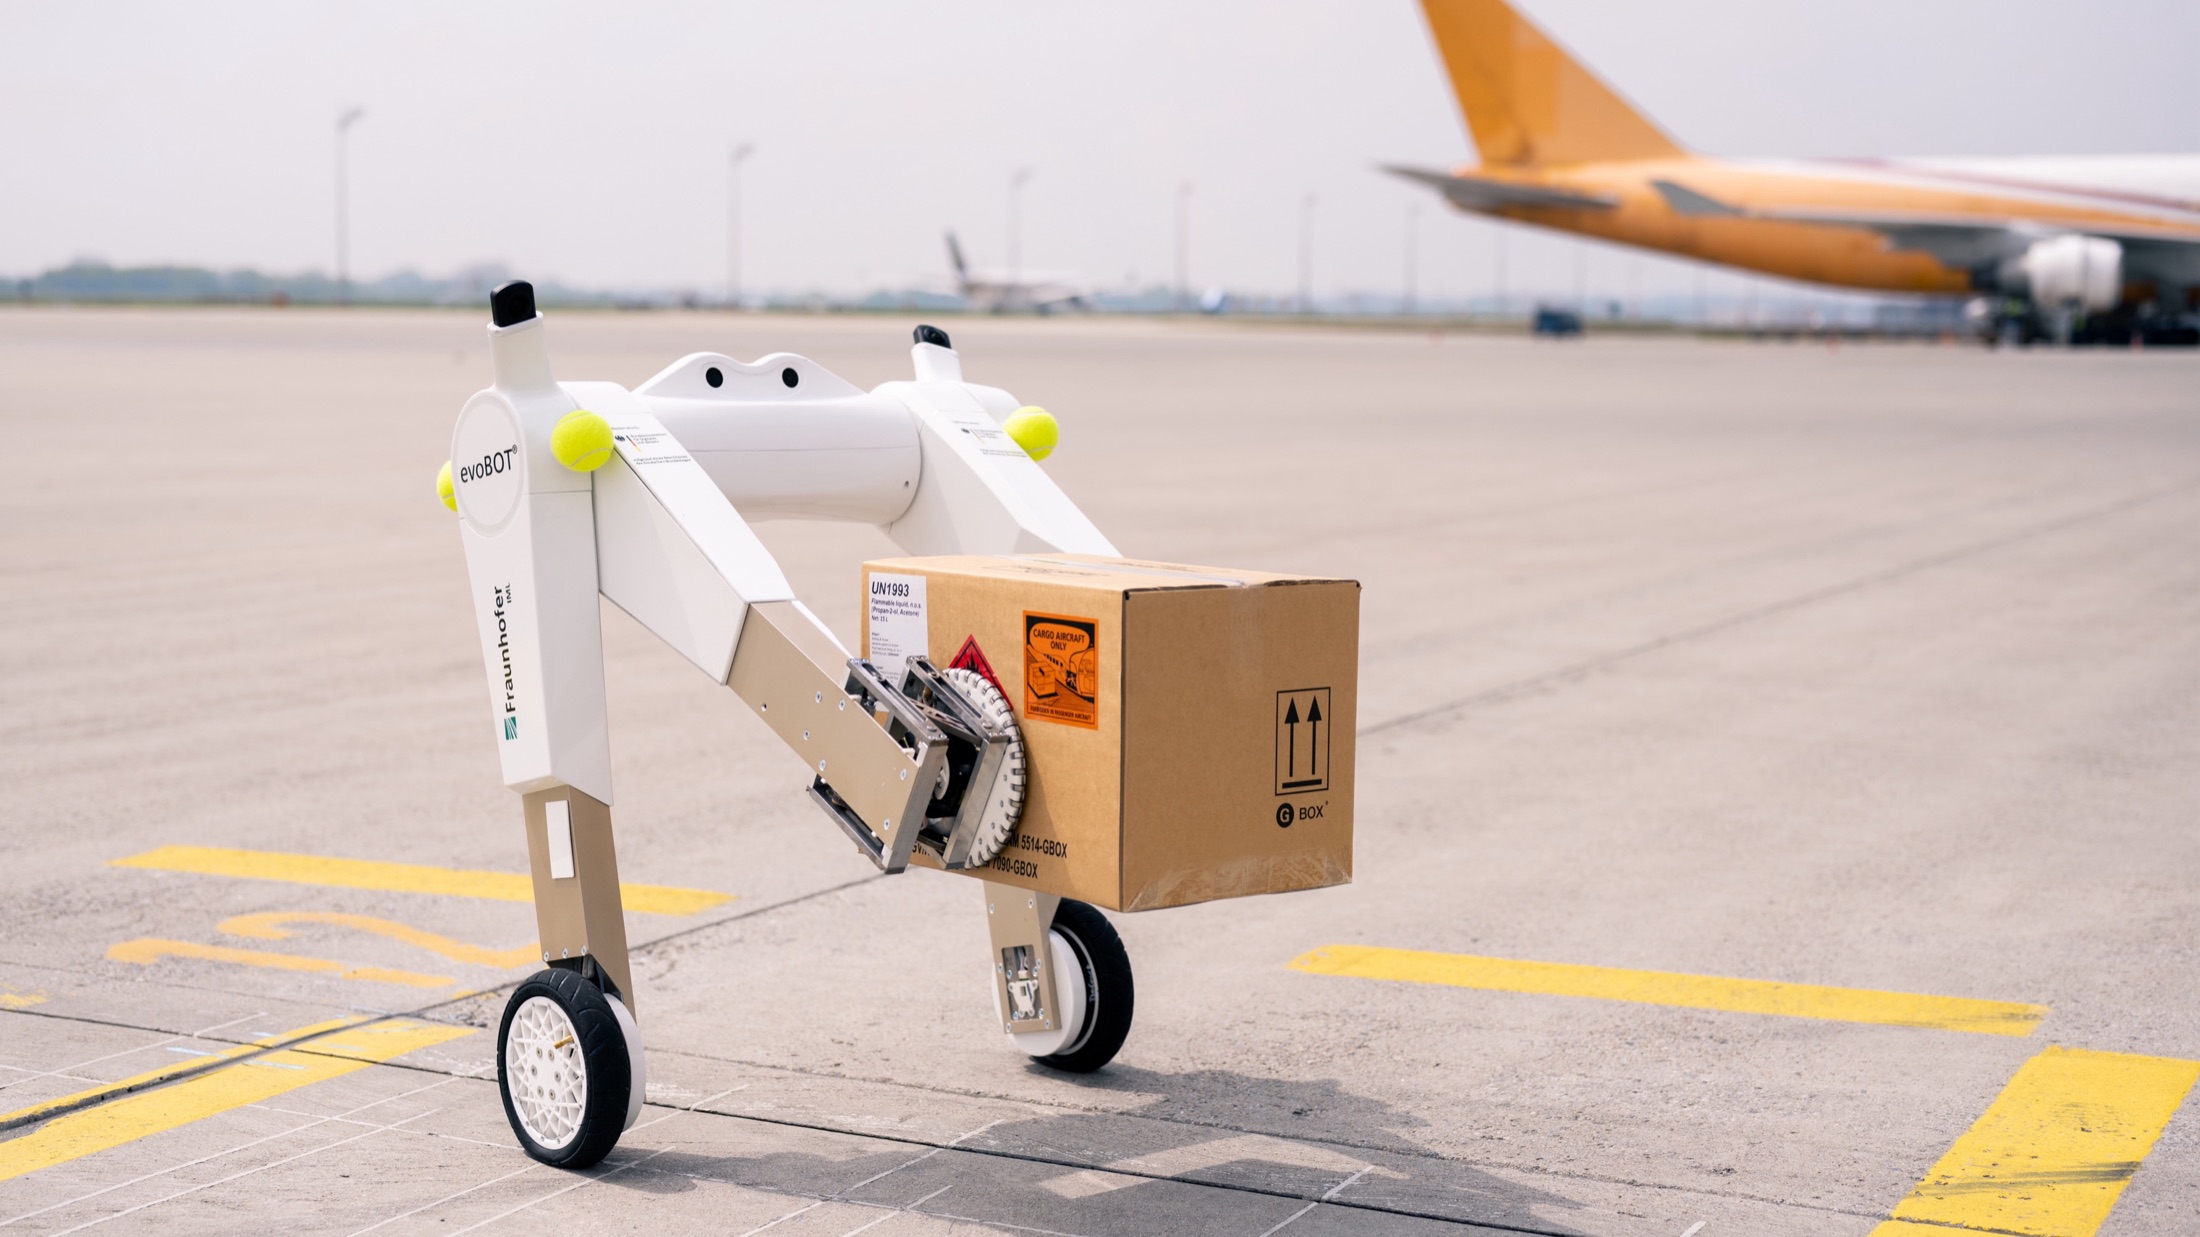
evoBOT transporting an air-cargo package on an airport apron.02

Dynamic mobile manipulation

evoBOT

A dynamically balancing, two-wheeled robot for handling and transporting loads.

Team achievement
A working prototype integrating balancing, manipulation and transport in one robotic system.
My contribution
I developed the initial idea and concept sketch, built the prototype with the team and led the first two years of core development. My technical focus was motion control, state estimation and system integration.
Published on media and peer reviewed conference: RSJ IROS
Open project →
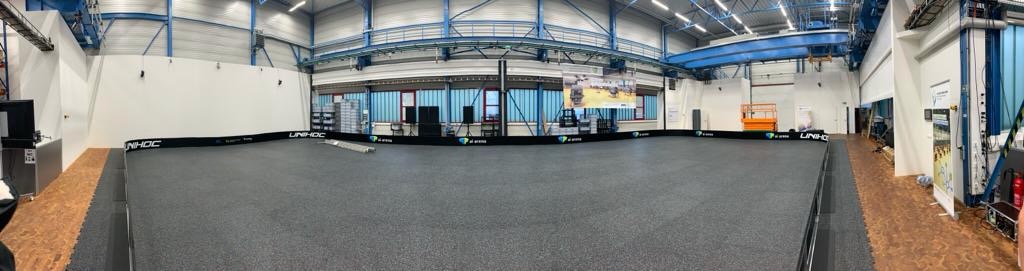
Wide panoramic view of the FLW cyber-physical research hall at TU Dortmund.03

Cyber-physical test field

Drone swarm & motion capture

I helped commission the motion-capture system and contributed to coordinated indoor-UAV experiments within the chair’s wider research team.

Open project →

Patents

Engineering ideas, documented.

I am a named inventor on 14 selected robotics patent families: thirteen associated with LoadRunner and one with evoBOT. They address practical problems in dynamic transport, localization, coordination and load handling.

Load stabilization through controlled directional changes

Controlling vehicle motion to stabilize the transported load.

DE 10 2019 122 052 B4

Image-based localization using floor features

Estimating vehicle position from observations of a speckled floor.

DE 10 2020 214 002 B3

Routing for coordinated transport robots

Planning routes for vehicles operating in a shared transport system.

DE 10 2020 214 005 A1

Receiving and transferring load carriers

Load-handling mechanisms and methods associated with evoBOT.

DE 10 2022 202 045 B4

Selected families, not a count of granted or currently active patents. Technical summaries are descriptive. Linked records provide the document details.

Explore all 14 families →

About

From control algorithms to working robots.

I’ve worked in applied robotics since 2016. I’m interested in the point where dynamics, estimation and coordinated motion have to work together on real hardware, not just as separate algorithms.

At Fraunhofer IML, I combine hands-on control-system development with technical team leadership. My doctoral research examines integrated control architectures for high-dynamic transport-robot swarms. I expect to complete my doctorate in March 2027.

Team Lead, High-Dynamic System ControlFraunhofer IML · Dortmund
Research AssociateFraunhofer IML · Dortmund
Research AssociateTU Dortmund University · Chair of Material Handling and Warehousing

2016 · M.Sc. Electrical Engineering and Information Technology · TU Dortmund University

2013 · B.Sc. Electrical Engineering and Information Technology · TU Dortmund University

Selected publications

First author · IEEE/RSJ IROS 2023

evoBOT: Design and Learning-Based Control of a Two-Wheeled Compound Inverted Pendulum Robot

View DOI ↗
Co-author · Logistics Research 16:11 · 2023

Micro UAV Swarm for industrial applications in indoor environment: A Systematic Literature Review

View DOI ↗

Full background in my CV ↓Google Scholar ↗

Contact

Let’s talk robotics.

Building a technical team around control, estimation or coordinated robot systems? I’d be glad to discuss the engineering challenges.

patrick.klokowski@gmail.com ↗