Project 01 · High-dynamic logistics

LoadRunner

Vehicle-level control. Fleet-level coordination.

A high-speed omnidirectional transport-robot system designed to combine the flexibility of mobile robots with the throughput of fixed sorting technology.

Fraunhofer IMLTeam-built research platformDPD field trial · 2023
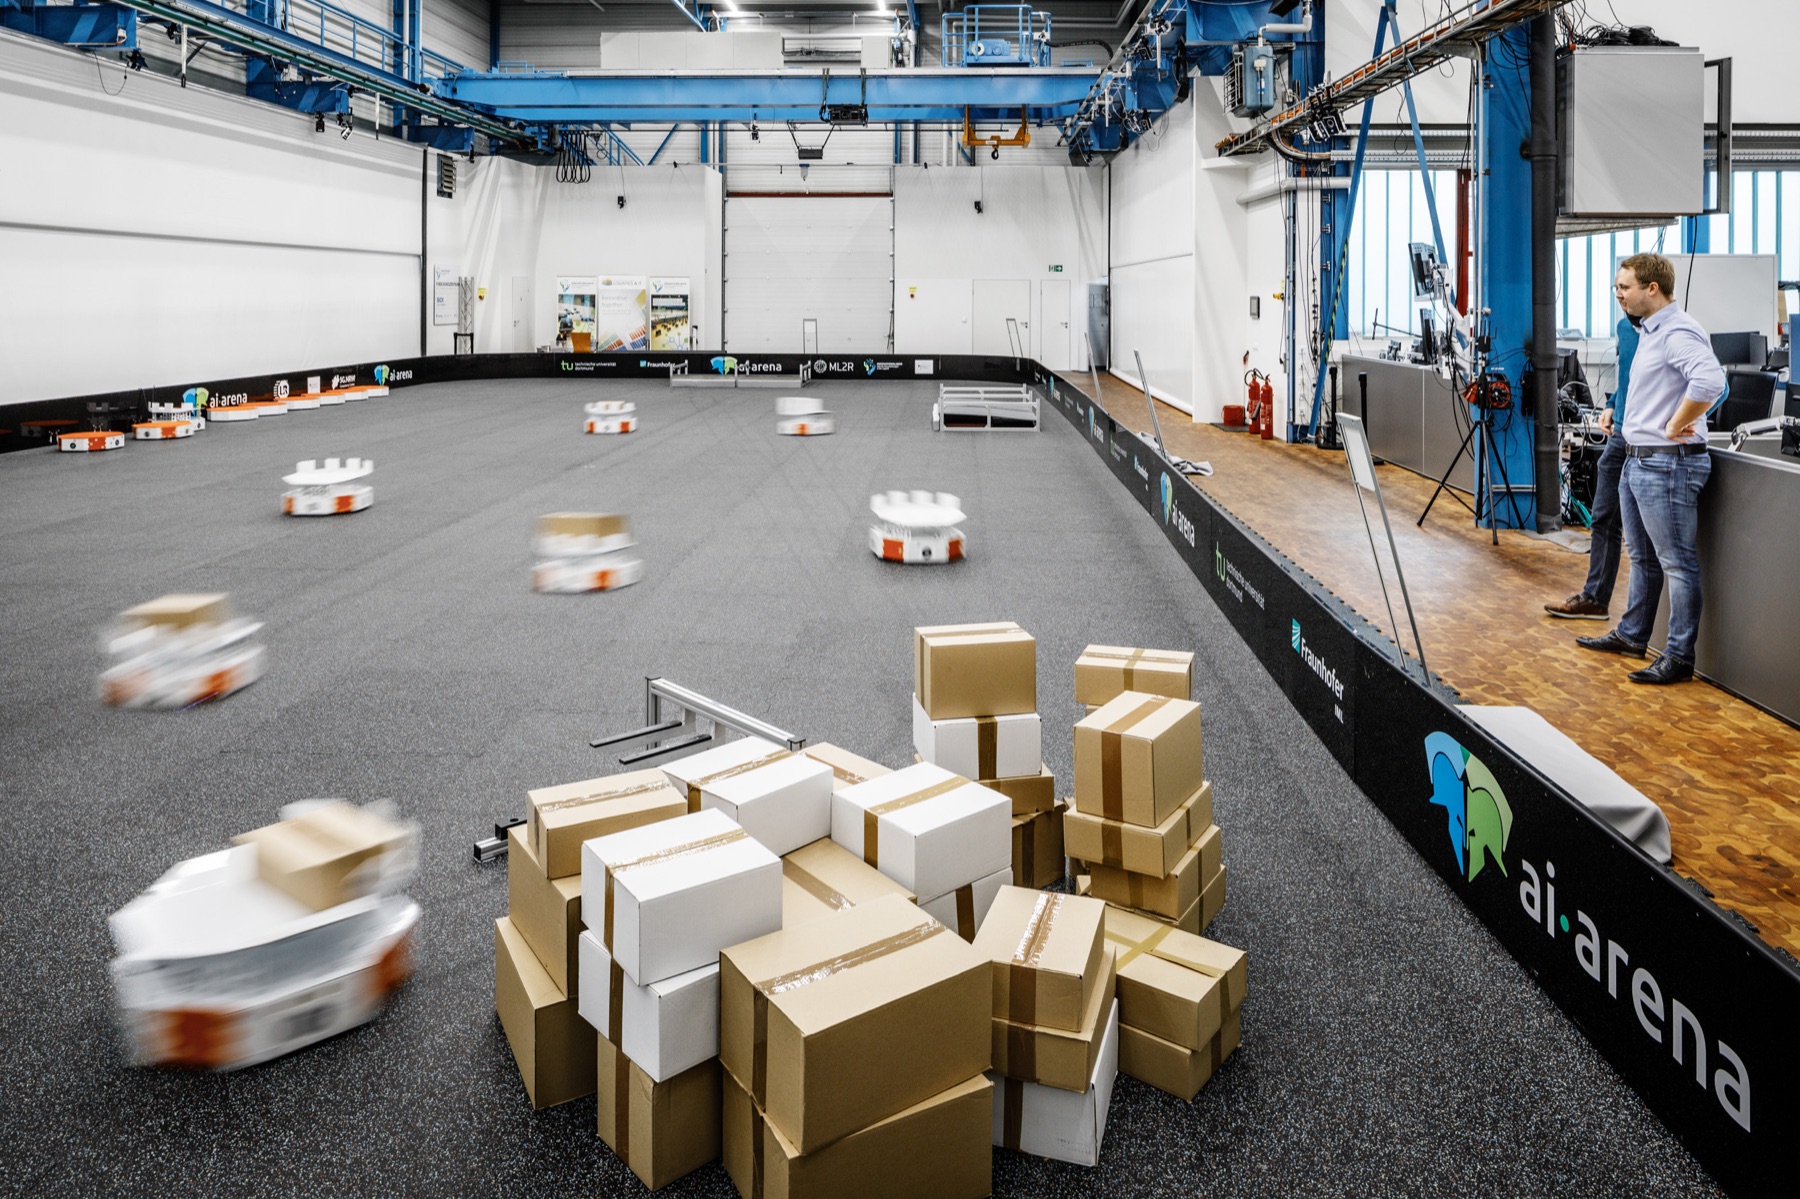
LoadRunner robots sorting parcels as a coordinated fleet in a research hall.
LoadRunner fleet in a parcel-sorting research scenario.Image credit pending final confirmation

The platform

Flexible robots at sorting-system speed.

LoadRunner combines high vehicle dynamics with decentralized transport. The omnidirectional robots move without fixed routes, coordinate their motion and can transport loads individually or in coupled formations.

10 m/s
reported maximum speed
5 m/s²
reported acceleration
≈30 kg
reported payload per vehicle

Published platform specifications. They do not describe a measured result from every trial.

Attribution

Team achievement

A multidisciplinary robotic system.

LoadRunner integrates mechanics, electronics, localization, control, communication, fleet coordination, logistics design, simulation and experimental validation. The platform and its transfer activities are the work of a broad Fraunhofer IML team and its partners.

My contribution

Concept and working control software.

I helped shape the LoadRunner concept and implemented its feedback controllers, state estimator, trajectory generator and fleet orchestration. My work connected vehicle-level motion with coordinated fleet operation.

Technical approach

Four connected layers.

This is a functional overview of my contribution areas, not a literal block diagram of the complete deployed architecture.

Feedback control

Track commanded vehicle motion under the constraints of a highly dynamic omnidirectional platform.

State estimation

Turn sensor observations into a reliable representation of vehicle motion for the control system.

Trajectory generation

Create feasible reference motion that respects dynamic limits and the transport task.

Fleet orchestration

Coordinate individual vehicles and connect local motion to system-level transport behavior.

Field evidence

From study to operational trial.

A published study modeled more than 10,000 parcels per hour with 60 vehicles. In 2023, the platform was tested under realistic conditions at DPD’s Cologne-Porz depot. In 2024, the project received the euRobotics Technology Transfer Award.

No connection to YouTube is made until the button is activated. Open on YouTube instead ↗